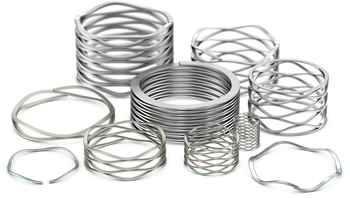
Spring Design Introduction
Gain a high-level understanding of wave spring design, performance characteristics, and engineering considerations such as load and deflection, operating stress, fatigue life, and spring rate. This introductory resource provides the foundation for evaluating wave spring solutions and links to more in-depth design methodologies, calculations, and application guidance based on specific engineering requirements.
Standard Springs vs Custom Springs
Finding the right spring can be as easy as selecting a standard catalog item. A Smalley engineer can help you choose from over 4000 standard parts available from stock in carbon and stainless steel. Smalley’s edgewinding manufacturing provides the utmost in flexibility and quality. Whether the requirement is for one spring or one million, consider Smalley for your special spring requirements.
Defining the Spring Requirements
Although wave spring applications are extremely diverse, there is a consistently basic set of rules for defining spring requirements. Those requirements are used to select a stock/standard spring or design a custom spring to meet the specifications.
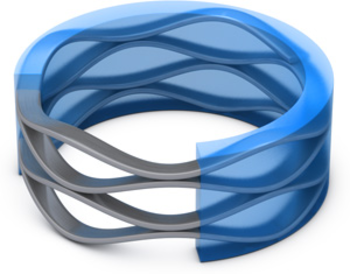
Wave Spring Design Considerations
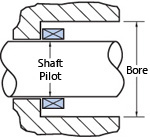
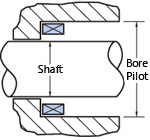
The working cavity usually consists of a bore the spring operates in and/or a shaft the spring clears. The spring stays positioned by piloting in the bore or on the shaft. The distance between the loading surfaces defines the axial working cavity or work height of the spring.
Material cross-section plays an important role in wave spring design. Economical materials ,such as carbon steel, are used in manufacturing Smalley standard parts. In addition, many other material cross sections are commonly used in special spring manufacture designs. Smalley engineering can provide assistance in selecting an economical alloy and cross section.
For Overlap Type Wave Springs and multiple turn Spirawave, the radial wall must be sufficient to prevent misalignment between adjacent layers. For springs with a narrow radial wall, radial misalignment can occur during handling or operation if the spring is not contained or closely piloted.
Solutions to this problem include dimensioning the spring to pilot closely on the I.D. and/or O.D. or designing the spring as a single turn Gap Type.
For springs that pilot on a shaft, the inside diameter can be toleranced to provide a minimum clearance from the shaft. Since wave springs expand during compression, interference with the shaft is generally not a concern.
For springs that pilot in the bore, the bore and shaft diameters should be included in the spring specifications. The actual spring diameter is then developed at time of manufacture to provide the best fit and prevent binding due to expansion.
For Gap Type and Overlap Type Springs, the outside diameter can be specified because binding is not a concern. The outside diameter can be toleranced to provide a minimum clearance in the bore or provide cling in the bore, as do the Smalley Bearing Preload Springs.
The load requirement is defined by the amount of axial force the spring must produce when installed at its work height. Some applications require multiple working heights, where loads at 2 or more operating heights are critical and must be considered in the design. Often minimum and/or maximum loads are satisfactory solutions, particularly where tolerance stack-ups are inherent in the application.
High temperature, dynamic loading (fatigue), corrosive media or other unusual operating conditions must be considered in spring applications. Solutions to various environmental conditions typically require selection of the optimal raw material and operating stress.
Calculating Spring Performance
Compressing a wave spring creates bending stresses similar to a simple beam in bending. These compressive and tensile stresses limit the amount a spring can be compressed before it yields or “takes a set”. Although spring set is sometimes not acceptable, load and deflection requirements will often drive the design to accept some set or “relaxation” over time.
Static Applications: Smalley utilizes the Minimum Tensile Strength found within our tables of standard springs to approximate yield strength due to the minimal elongation of the hardened flat wire used in Smalley products. When designing springs for static applications, we recommend the calculated operating stress be no greater than 100% of the minimum tensile strength. However, depending on certain applications, operating stress can exceed the minimum tensile strength with allowances for yield strength. Typical factors to consider are permanent set, relaxation, loss of load and/or loss of free height.
Dynamic Applications: When designing wave springs for dynamic applications, Smalley recommends that the calculation of operating stress not exceed 80% of the minimum tensile strength.
Increasing the load capacity and/or fatigue life can be achieved by compressing a spring beyond its elastic yield point or “presetting”. Preset springs are manufactured to a greater free height and load which is then compressed solid. Both the free height and load are reduced and the material surfaces now exhibit residual stresses, which enhance spring performance.
Fatigue cycling is an important consideration in wave spring design. Determining precisely how much a spring will deflect can greatly impact the price of the spring. An analysis should include whether the spring deflects full stroke, only a few thousandths each cycle, or possibly a combination of both as parts wear or temperature changes.
Formula:
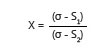
| Fatigue Stress Ratio | Estimated Cycle Life |
| .00 < X < .40 | Under 30,000 cycles |
| .40 < X < .49 | 30,000 - 50,000 cycles |
| .50 < X < .55 | 50,000 - 75,000 cycles |
| .56 < X < .60 | 75,000 - 100,000 cycles |
| .61 < X < .67 | 100,000 - 200,000 cycles |
| .68 < X <.70 | 200,000 - 1,000,000 cycles |
| .70 < X | over 1,000,000 cycles |
Nomenclature
σ = Material tensile strength
S1 = Calculated operating stress at lower work height
S2 = Calculated operating stress at upper work height
You may use the Spring Design Calculator to quickly determine operating stresses and approximate cycle life, or the equations can be found on the Single Turn Gap or Overlap and Multiple Turn (Crest‑to‑Crest) Spirawave pages.
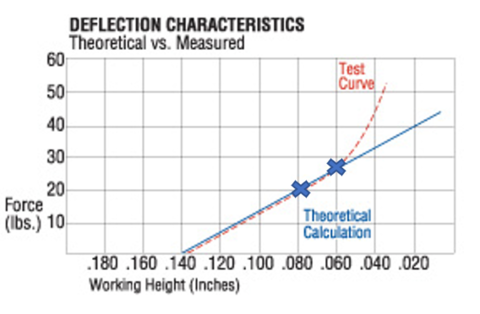
A comparison of the actual spring rate to the theoretical (calculated) spring rate provides practical limits for the working range of the spring. Spring rate (P/f) can be calculated by manipulating the deflection equations. Typically, theoretical rate is accurate until the spring starts to bottom out or reach its “solid height”.
As a general rule, the calculated spring rate is linear through the first 80% of available deflection and for work heights down to 2 times the solid height. Although the spring can operate beyond this “linear” range, measured loads will be much higher than calculated.
More information about Single Turn Gap or Overlap, Multiple Turn (Crest‑to‑Crest) Spirawave, and Nested Spirawave parts can be found on their pages.
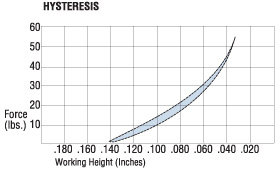
Wave springs exert a greater force upon loading and lower force upon unloading. This effect is known as hysteresis. The shaded area shows a graphic representation between the curves.
In a single turn spring, friction due to circumferential and radial movements are the prime causes. Crest-to-Crest and Nested Springs also contribute to the frictional loss as adjacent layers rub against each other. Sufficient lubrication will minimize this effect.
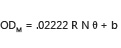
Nested and Crest-to-Crest Spirawaves only: Multiple turn Spirawaves expand in diameter when compressed. The formula shown below is used to predict the maximum fully compressed diameter.
Formula:
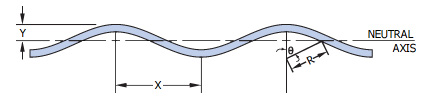
Nomenclature
ODM = Outside diameter at solid (in)
R = Wave radius (in) = (4Y2 + X2)/8Y
N = Number of waves
θ = Angle = ArcSin[X/(2R)] (degrees)
b = Radial wall (in)
X = 1/2 wave frequency = (πDM)/(2N)
Y = 1/2 mean free height = (H-t)/2
Where H = Free height per turn (in)
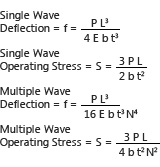
Linear Springs are a continuous wave formed (marcelled) wire length produced from spring temper materials. They act as a load bearing device having approximately the same load/deflection characteristics as a wave spring.
Forces act axially or radially depending on the installed position. Axial pressure is obtained by lying the expander flat in a straight line. Circular wrapping the expander (around a piston for example) produces a radial force or outward pressure.
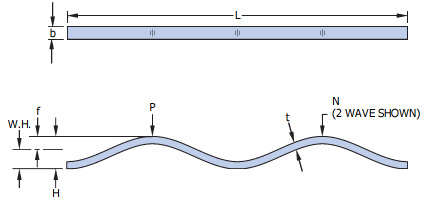
Spring Design Formulas
Single Turn Gap or Overlap Type
- Low-Medium Force
- Low-Medium Spring Rate
- Short Deflection
- Precise Load/Deflection Characteristics
Single turn wave springs are used in the widest variety of spring applications due to their lower cost and simplified design configuration. They provide the most flexibility to designers. There are few restrictions in their design and they are specified in the majority of small axial and radial space constraint applications.
Equations:
Deflection:
f = (P K Dₘ³) / (E b t³ N⁴) × (I.D. / O.D.)
Operating Stress:
S = (3π P Dₘ) / (4 b t² N²)
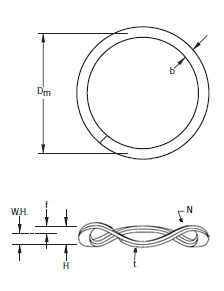
Nomenclature
b = Radial Wall, in. [(O.D. - I.D.)÷2]
Dm = Mean Diameter (in) [(O.D. + I.D.)÷2]
E = Modulus of Elasticity (psi)
f = Deflection (in.)
H = Free Height (in.)
I.D. = Inside Diameter (in.)
K = Multiple Wave Factor
L = Length, overall linear (in.)
N = Number of Waves (per turn)
O.D. = Outside Diameter (in.)
P = Load (lb.)
S = Operating Stress (psi)
t = Thickness of Material (in.)
W.H. = Work Height (in.) [H-F]
Z = Number of turns
|
Multiple Wave Factor (K) |
||||
| N | 2.0 - 4.0 | 4.5 - 6.5 | 7.0 - 9.5 | 10.0 + |
| K | 3.88 | 2.90 | 2.30 | 2.13 |
Crest-To-Crest
- Low-Medium Force
- Low-Medium Spring Rate
- Long Deflection
- Precise Load/Deflection Characteristics
Crest-to-Crest Spirawave flat wire compression springs are pre-stacked in series, decreasing the spring rate by a factor relative to the number of turns.
Equations:
Deflection = f = (P K Dₘ³ Z / E b t³ N⁴) × (I.D. / O.D.)
Operating Stress = S = (3 π P Dₘ) / (4 b t² N²)
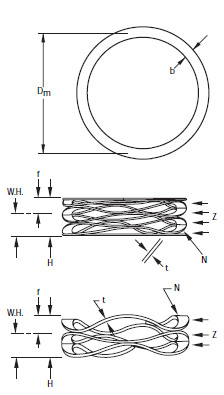
Nomenclature
b = Radial Wall, in. [(O.D. - I.D.) ÷ 2]
Dm = Mean Diameter, in. [(O.D. + I.D.) ÷ 2]
E = Modulus of Elasticity (psi)
f = Deflection (in.)
H = Free height (in.)
I.D. = Inside Diameter (in.)
K = Multiple Wave Factor
L = Length, overall Linear (in.)
N = Number of Waves (per turn)
O.D. = Outside Diameter (in.)
P = Load (lb.)
S = Operating Stress (psi)
t = Thickness of Material (in.)
W.H. = Work Height (in.) [H-f]
Z = Number of Turns
|
Multiple Wave Factor (K) |
|||||
| N | 2.0 - 4.0 | 4.5 - 6.5 | 7.0 - 9.5 | 10.0+ | N |
| K | 3.88 | 2.90 | 2.30 | 2.13 |
K |
Nested Spirawave
- High Force
- High Spring Rate
- Short Deflection
- Precise Load/Deflection Characteristics
Nested Spirawave Wave Springs are flatwire wave springs with multiple turns that are aligned in parallel, increasing the spring rate by a factor related to the number of turns.
Equations:
Deflection = f = (P K Dₘ³) / (E b t³ N⁴ Z) × (I.D. / O.D.)
Operating Stress = S = (3 π P Dₘ) / (4 b t² N² Z)
Nomenclature
b = Radial Wall, in. [(O.D. - I.D.) ÷ 2]
Dm = Mean Diameter, in. [(O.D. + I.D.) ÷ 2]
E = Modulus of Elasticity (psi)
f = Deflection (in.)
H = Free height (in.)
I.D. = Inside Diameter (in.)
K = Multiple Wave Factor
L = Length, overall Linear (in.)
N = Number of Waves (per turn)
O.D. = Outside Diameter (in.)
P = Load (lb.)
S = Operating Stress (psi)
t = Thickness of Material (in.)
W.H. = Work Height (in.) [H-f]
Z = Number of Turns
|
Multiple Wave Factor (K) |
||||
|
N |
2.0 - 4.0 |
4.5 - 6.5 |
7.0 - 9.5 |
10.0+ |
|
K |
3.88 |
2.9 |
2.3 |
2.13 |